
Humanoid robots
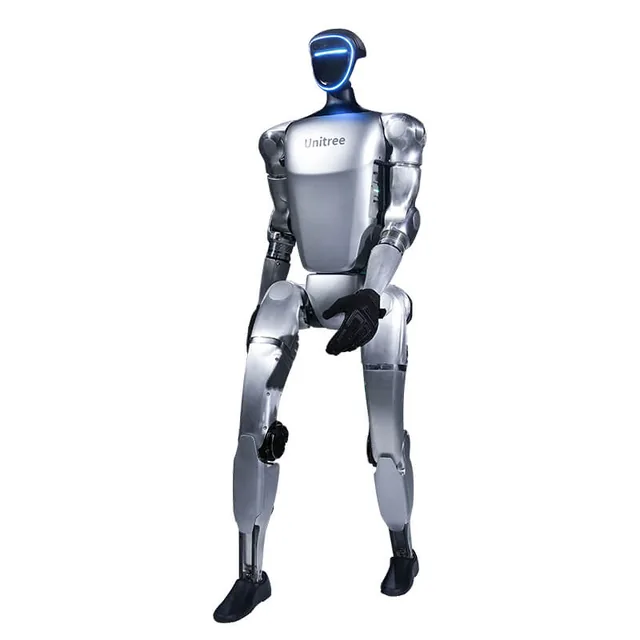
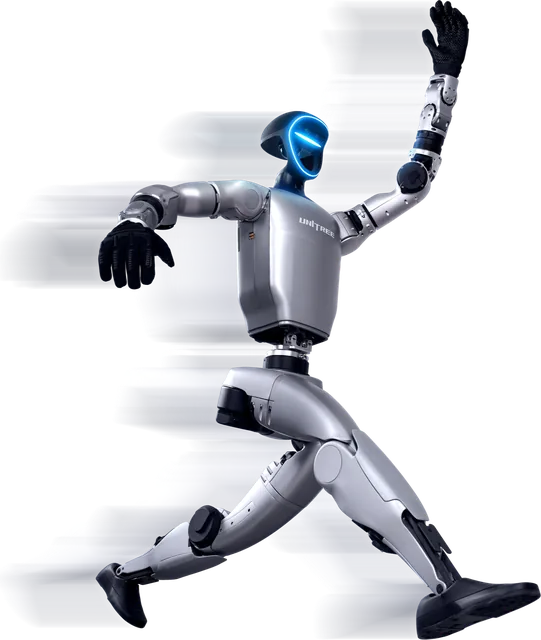
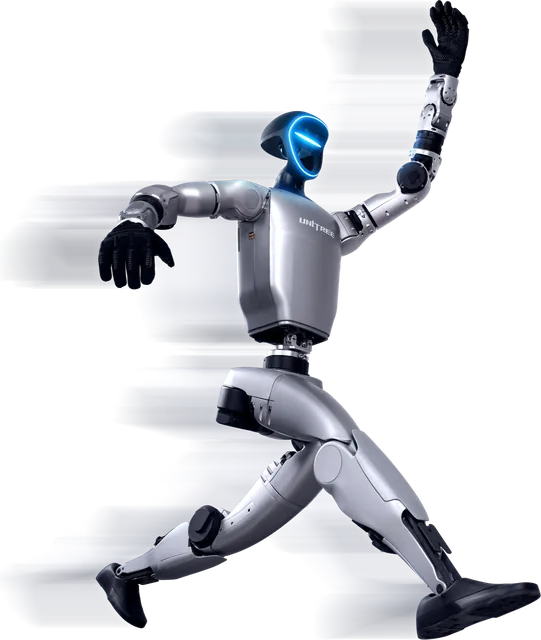
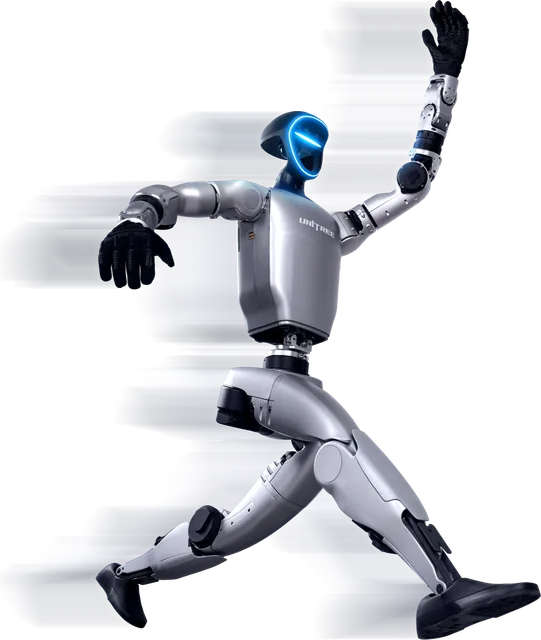
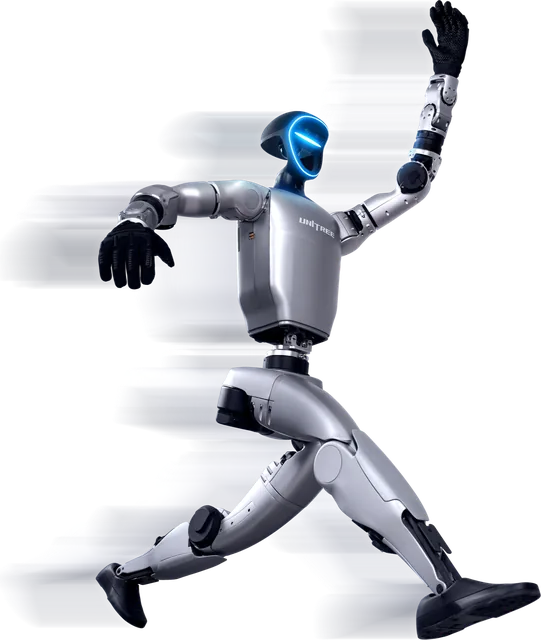
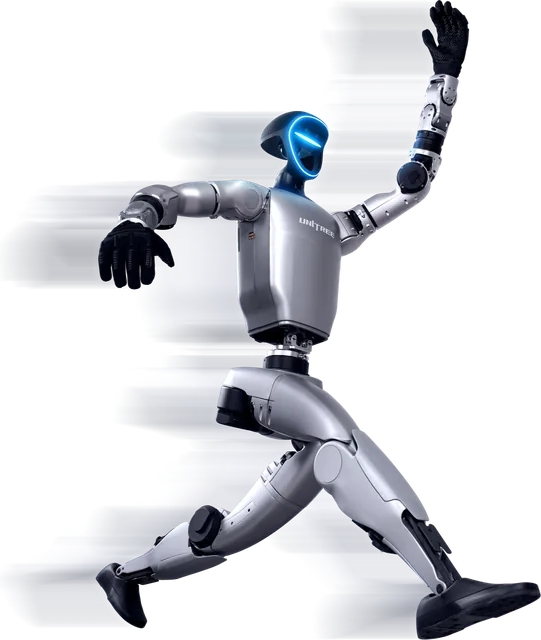
Unitree G1 Basic Humanoid Robot
Versatile 1.32 m, approx. 35 kg humanoid with 23 degrees of freedom, foldable, for service, commercial and academic applications.
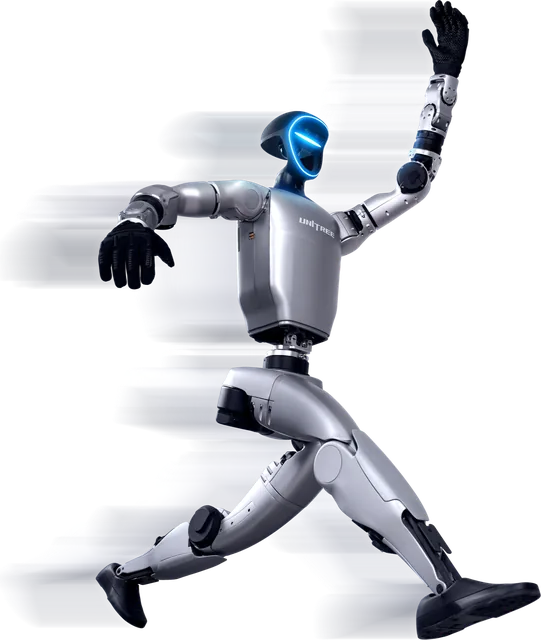
Unitree Robotics · Humanoid robots
G1 EDU Standard equipped with Wuji Hand 2 dexterous hands and wrist camera, for manipulation research.
| Dimensiones (de pie) | 1320 x 450 x 200 mm |
|---|---|
| Dimensiones (plegado) | 690 x 450 x 300 mm |
| Peso (con batería) | Aprox. 35 kg+ |
| Grados de libertad totales | 23 - 43 |
| GdL por pierna / brazo | 6 / 5 |
| GdL de cintura | 1 (opcional +2) |
| GdL por mano | 7 (mano de 3 dedos opcional) + 2 de muñeca opc. |
| Torque máx. de rodilla | 120 N·m |
| Carga máx. del brazo | Aprox. 3 kg |
| Longitud pierna (muslo + pantorrilla) | 0.6 m |
| Envergadura del brazo | Aprox. 0.45 m |
| Rango articular | Cintura Z±155° X±30° Y±30°; rodilla 0~165°; muñeca ±92.5° |
| Procesador | CPU de 8 núcleos de alto rendimiento |
| Sensors | Cámara de profundidad + LiDAR 3D; 4 micrófonos; altavoz 5 W |
| Batería | Litio 13S, 9000 mAh (liberación rápida); autonomía aprox. 2 h |
| Cargador / conectividad | 54 V 5 A; Wi-Fi 6, Bluetooth 5.2 |
Datos de referencia del modelo. Confirmamos la configuración exacta, voltaje y accesorios al cotizar.
Humanoid robots
Versatile 1.32 m, approx. 35 kg humanoid with 23 degrees of freedom, foldable, for service, commercial and academic applications.
Humanoid robots
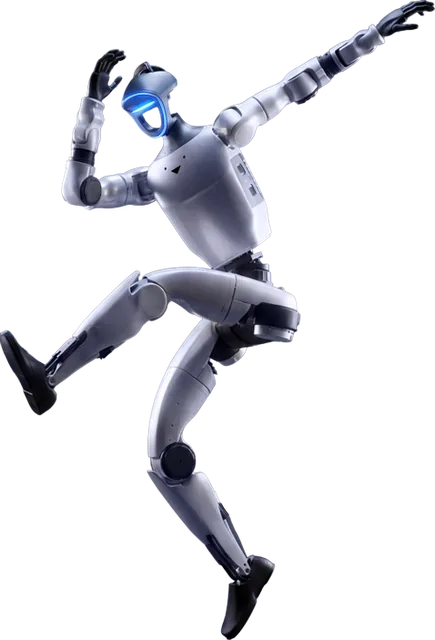
G1 with enhanced perception sensors and a full repertoire of moves and dances for tourism, retail and exhibitions.
Humanoid robots
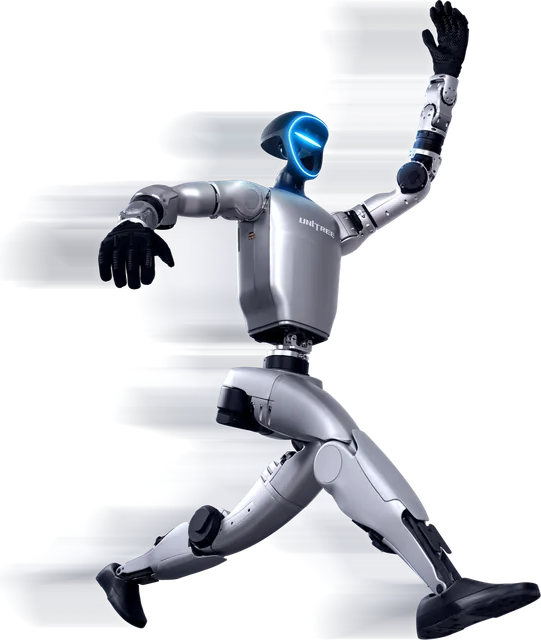
Commercial version of the G1 with all G1 Basic features plus the official moves and dances of the plus edition.
Humanoid robots
G1 humanoid research platform with secondary development support and open interfaces.
Humanoid robots
G1 EDU with more degrees of freedom and expanded computing for advanced embodied AI research.
Humanoid robots
G1 EDU Plus equipped with Dex3-1 dexterous hands without tactile sensing and a wrist camera, for dexterous manipulation research.
Humanoid robots
G1 EDU Plus equipped with Dex3-1 dexterous hands with tactile sensing and a wrist camera, for dexterous manipulation research.
Humanoid robots
G1 EDU Plus equipped with Inspire DFQ dexterous hands without tactile sensing and a wrist camera, for dexterous manipulation research.